

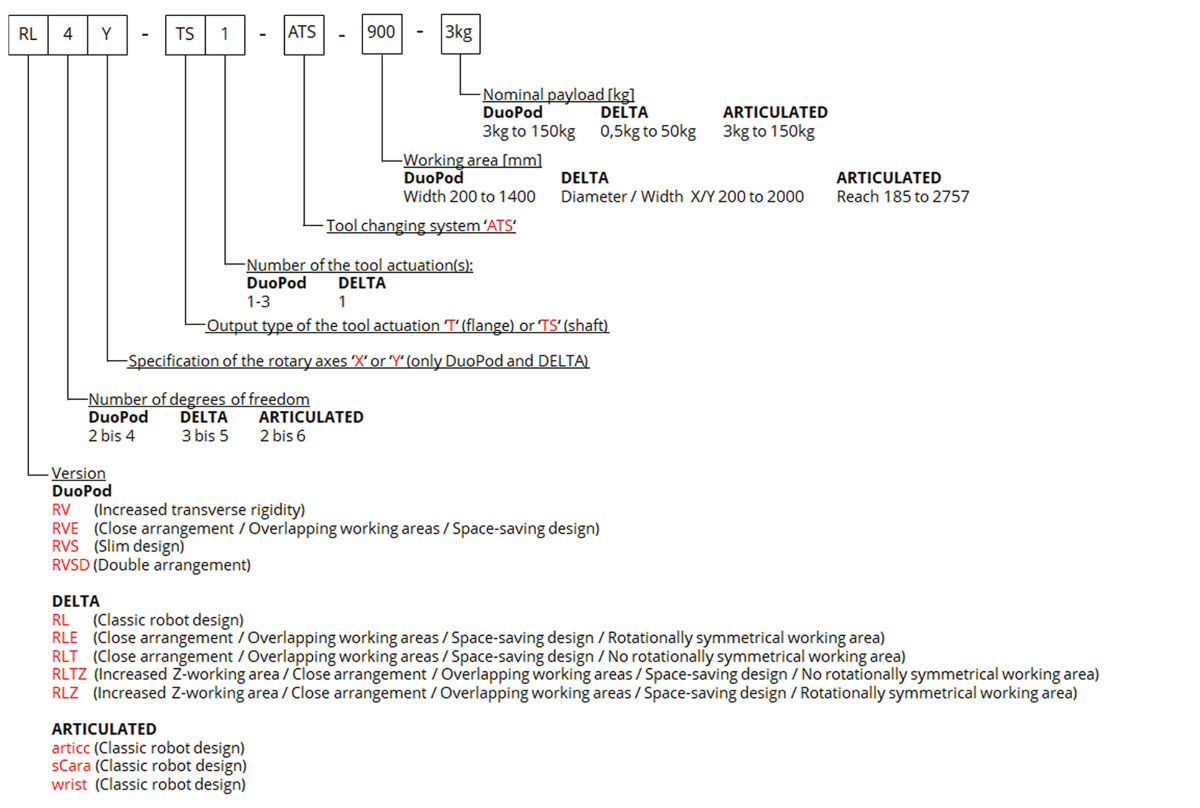

HHD DELTA RLT4-1250-3kg
Delivery time: on request
This type of robot is based on the principle of parallel kinematics.
All drives are mounted in a fixed position on the robot head. Motor cables are not moved. The robot has three (3) translational and one (1) rotational degree(s) of freedom.
Scope of delivery
- Robot mechanics incl. gearbox
- Servo motor adapter
- Transport and packing instructions
Note: The operating instructions and documentation on commissioning, service, maintenance, etc. are available in the password-protected download area of the respective product page (www.autonoxfinder.com).
-
Signed in / logged in you will receive further documents:
Note: If the documentation in the download area is not yet complete, please contact us (info@autonox.com).
| Field of application: | Hygienic ′HHD′ |
|---|---|
| Kinematics: | Parallel |
| Translatory Degrees of Freedom (X,Y,Z): | 3 |
| Rotational Degrees of Freedom (α,ß,γ): | 1 |
| Nominal payload [kg|lbs]: | 3 | 6.6 |
| Working area-width X/Y [mm|in]: | 805/1250 | 31.7/49.2 |
| Working height outside [mm|in]: | 150 | 5.9 |
| Working height center [mm|in]: | 250 | 9.8 |
| Max. acceleration torque of the rotation γ around Z at the output [Nm|in.lbs]: | 6 | 53.1 |
| Nominal torque of the rotation γ around Z at the output [Nm|in.lbs]: | 4,8 | 42.5 |
| Max. speed of the rotation γ around Z at the output [1/min]: | 800 |
| Nominal speed of the rotation γ around Z at the output [1/min]: | 460 |
| Bearing type of the telescopic shaft(s): | Roller bearing |
| Bearing type of the arm joints: | Roller bearing |
| Lubricants of the bearings: | Food-grade (FO) |
| Lubricants of the gearboxes: | Gearbox of the upper arms: Synthetic; gearbox of the telescopic shaft: Food-grade (FO) |
| Cleaning: | Up to 28 bar | 406 psi high pressure |
| Protection class: | IP69K |
| Ambient temperature [°C|°F]: | 0 to +40 | +32 to +104 |
| Relative humidity level [%]: | 95 (free of condensation) |
| Mounting position: | Ceiling, Wall (on request), Angle (on request) |
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | 8LSA36.DB060D200-3 |
| M2 | 8LSA36.DB060D200-3 |
| M3 | 8LSA36.DB060D200-3 |
| M4 | 8LSA26.D9060D200-3 |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | AM8042-0F21 |
| M2 | AM8042-0F21 |
| M3 | AM8042-0F21 |
| M4 | AM8023-0E21 |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | MS2S05-B0BTN-IMHG1-NNDNN-NN |
| M2 | MS2S05-B0BTN-IMHG1-NNDNN-NN |
| M3 | MS2S05-B0BTN-IMHG1-NNDNN-NN |
| M4 | MS2S03-B0BYN-IMHG1-NNDNN-NN |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
| M2 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
| M3 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
| M4 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | TA3S V60 BP05 EN01 PT |
| M2 | TA3S V60 BP05 EN01 PT |
| M3 | TA3S V60 BP05 EN01 PT |
| M4 | TA1M V60 BP03 EN01 PT |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | DMS2-091-0035-60-B1xxG1-Q000-0 |
| M2 | DMS2-091-0035-60-B1xxG1-Q000-0 |
| M3 | DMS2-091-0035-60-B1xxG1-Q000-0 |
| M4 | DMS2-058-0012-60-B1xxG1-Q000-0 |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | MCS09D60-EKMP1-Axxx-xx6xxx-xxxx |
| M2 | MCS09D60-EKMP1-Axxx-xx6xxx-xxxx |
| M3 | MCS09D60-EKMP1-Axxx-xx6xxx-xxxx |
| M4 | MCS06C60-EKMP1-Axxx-xx6xxx-xxxx |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | VPL-B1003T-PK14AA |
| M2 | VPL-B1003T-PK14AA |
| M3 | VPL-B1003T-PK14AA |
| M4 | VPL-B0633M-PK14AA |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | CMP63S/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.100 |
| M2 | CMP63S/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.100 |
| M3 | CMP63S/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.100 |
| M4 | CMP40M/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.800 |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation 1) |
Article number motor manufacturer (Recommendation 2) | Article number motor manufacturer (Recommendation 3) |
|---|---|---|---|
| M1 | 1FK2105-4AF11-0MA0 | 1FK2105-4AF11-0MB0 | 1FK7042-2AK71-1RH2 |
| M2 | 1FK2105-4AF11-0MA0 | 1FK2105-4AF11-0MB0 | 1FK7042-2AK71-1RH2 |
| M3 | 1FK2105-4AF11-0MA0 | 1FK2105-4AF11-0MB0 | 1FK7042-2AK71-1RH2 |
| M4 | 1FK2203-4AK10-2MA0 | 1FK2203-4AK10-2MB0 | 1FK7022-5AK71-1LH5 |
No motors are currently defined. Enquire here
Axis |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | SGM7A-10D7F2C |
| M2 | SGM7A-10D7F2C |
| M3 | SGM7A-10D7F2C |
| M4 | SGM7A-04D7F2C |
No motors are currently defined. Enquire here

This device is used to calibrate our robot mechanics. A defined motor position (encoder value) is assigned to the respective mechanical axis position. The calibration instructions can be found in the download area of the respective robot mechanics.
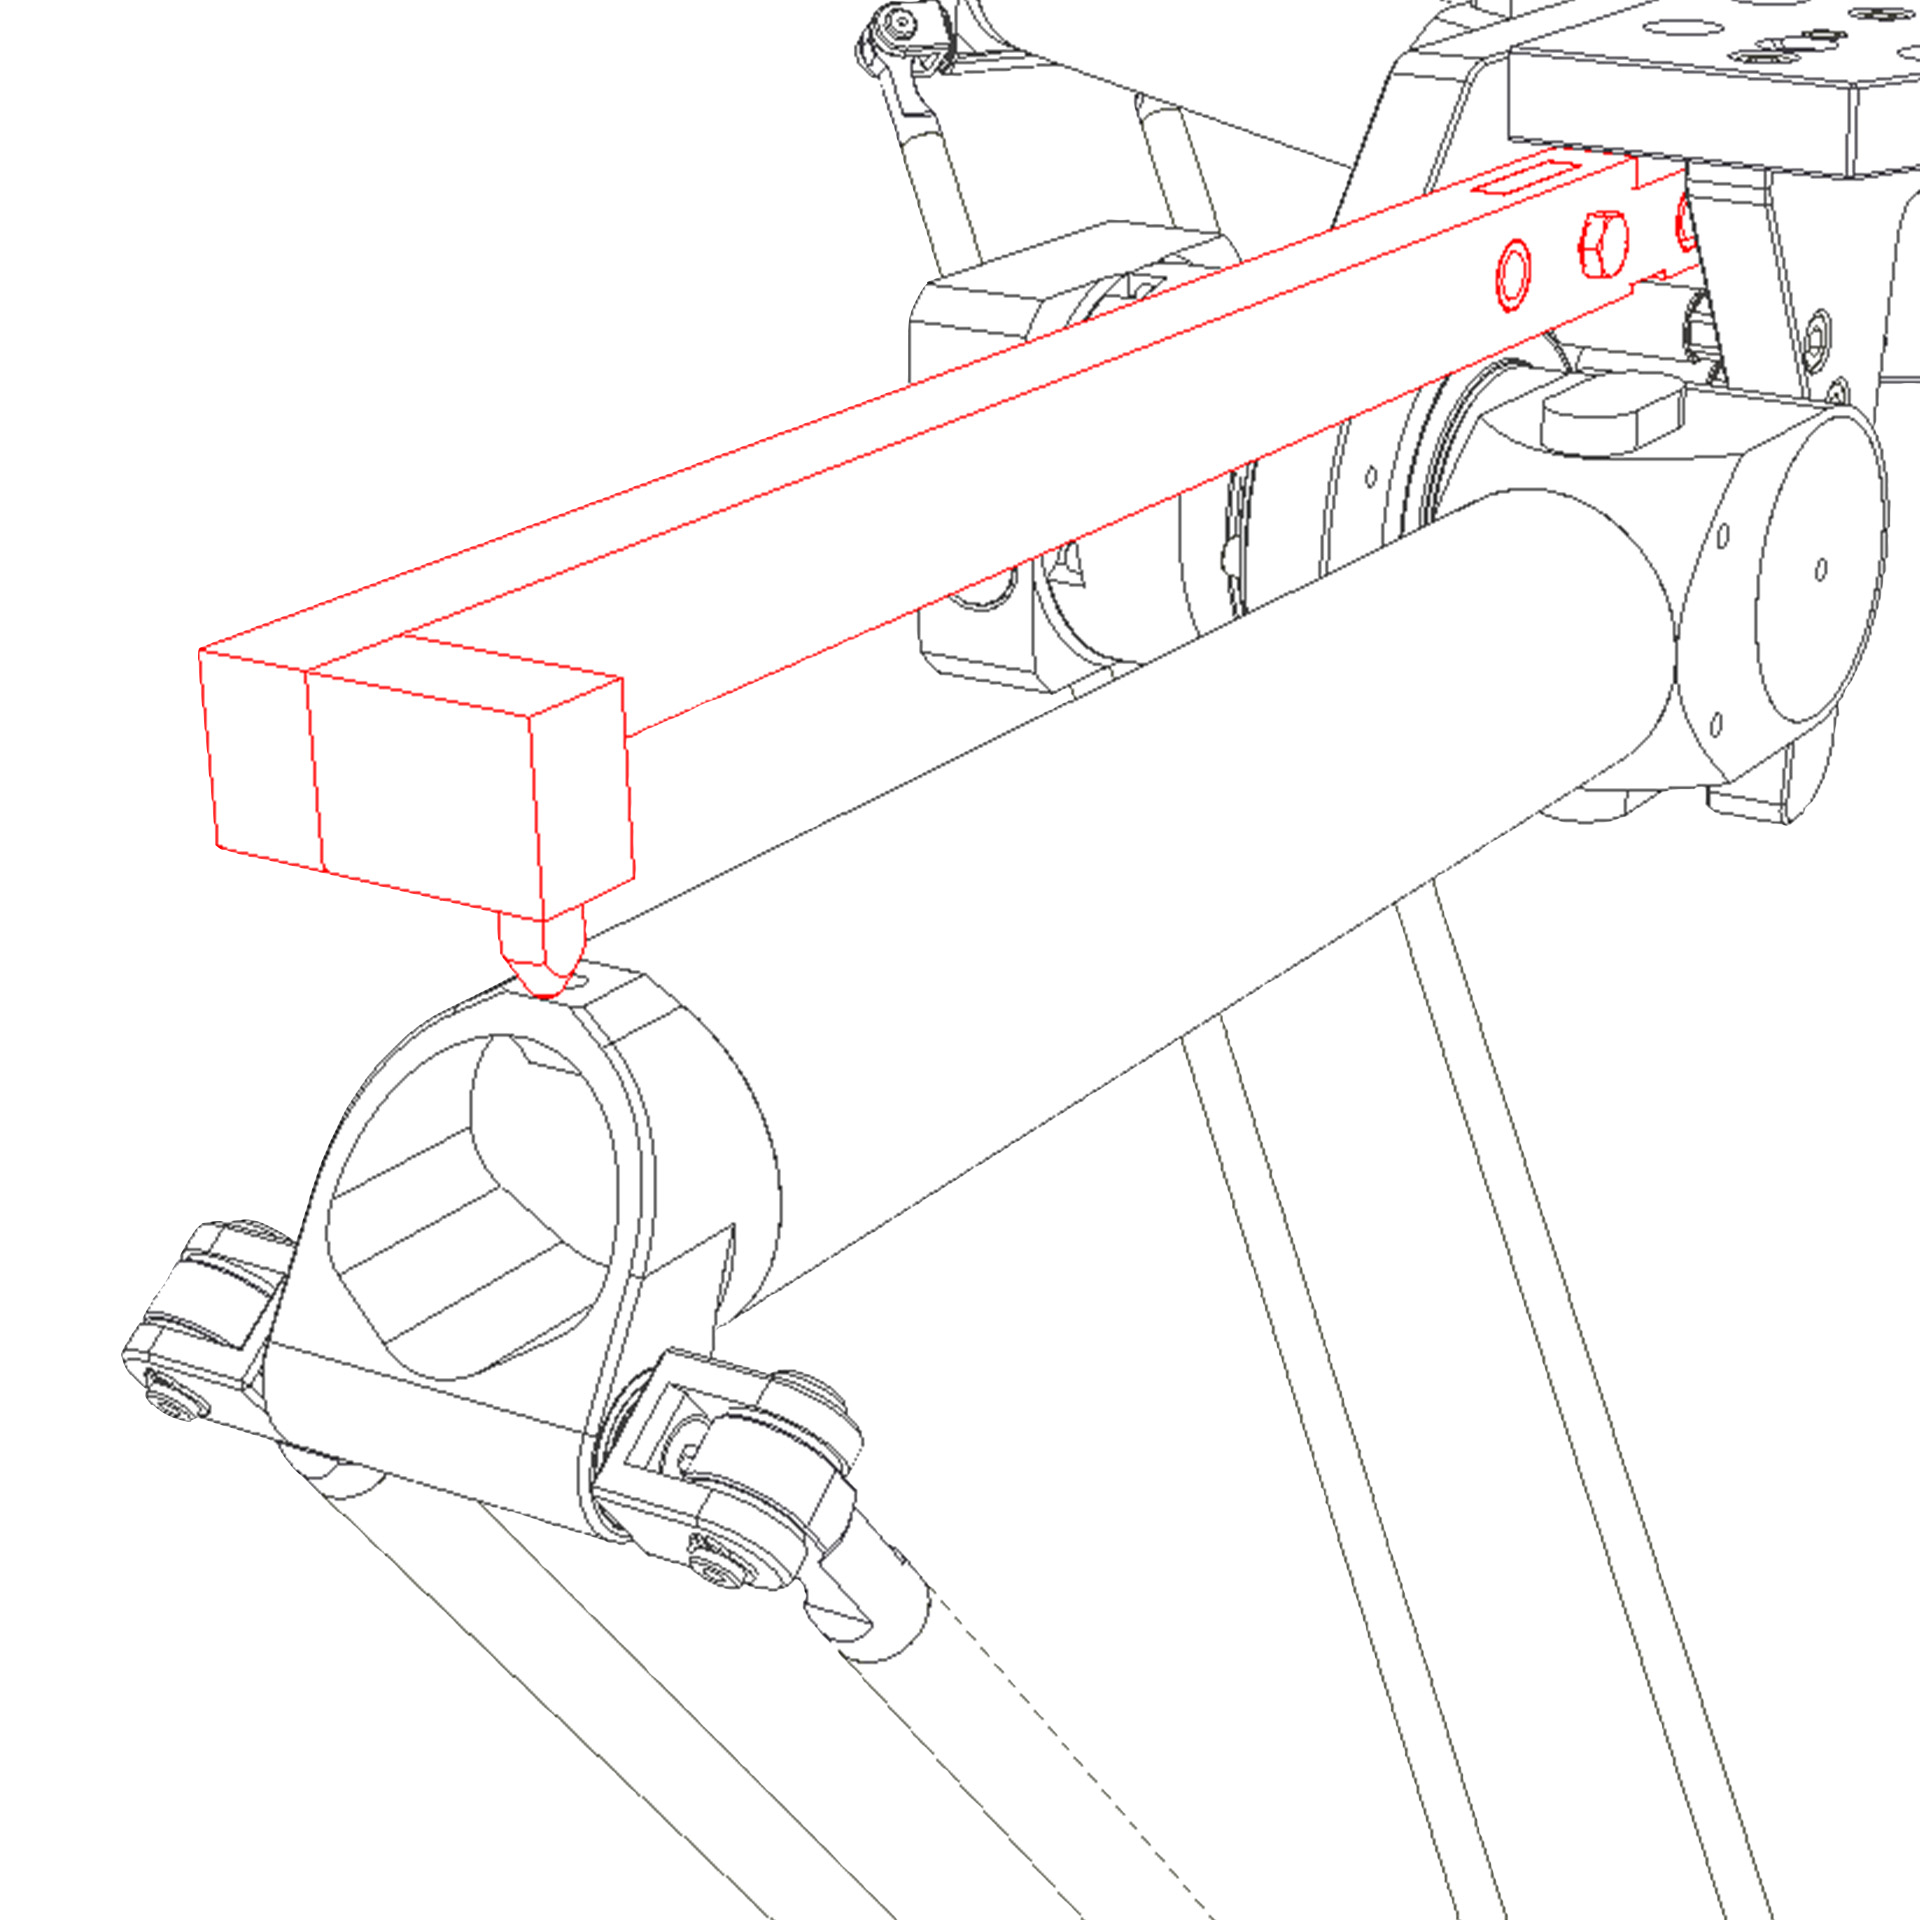
- Calibration device
- Mounting set (consisting of: Screw(s) and/or pin(s))

This device is used to calibrate our robot mechanics. A defined motor position (encoder value) is assigned to the respective mechanical axis position. The calibration instructions can be found in the download area of the respective robot mechanics.
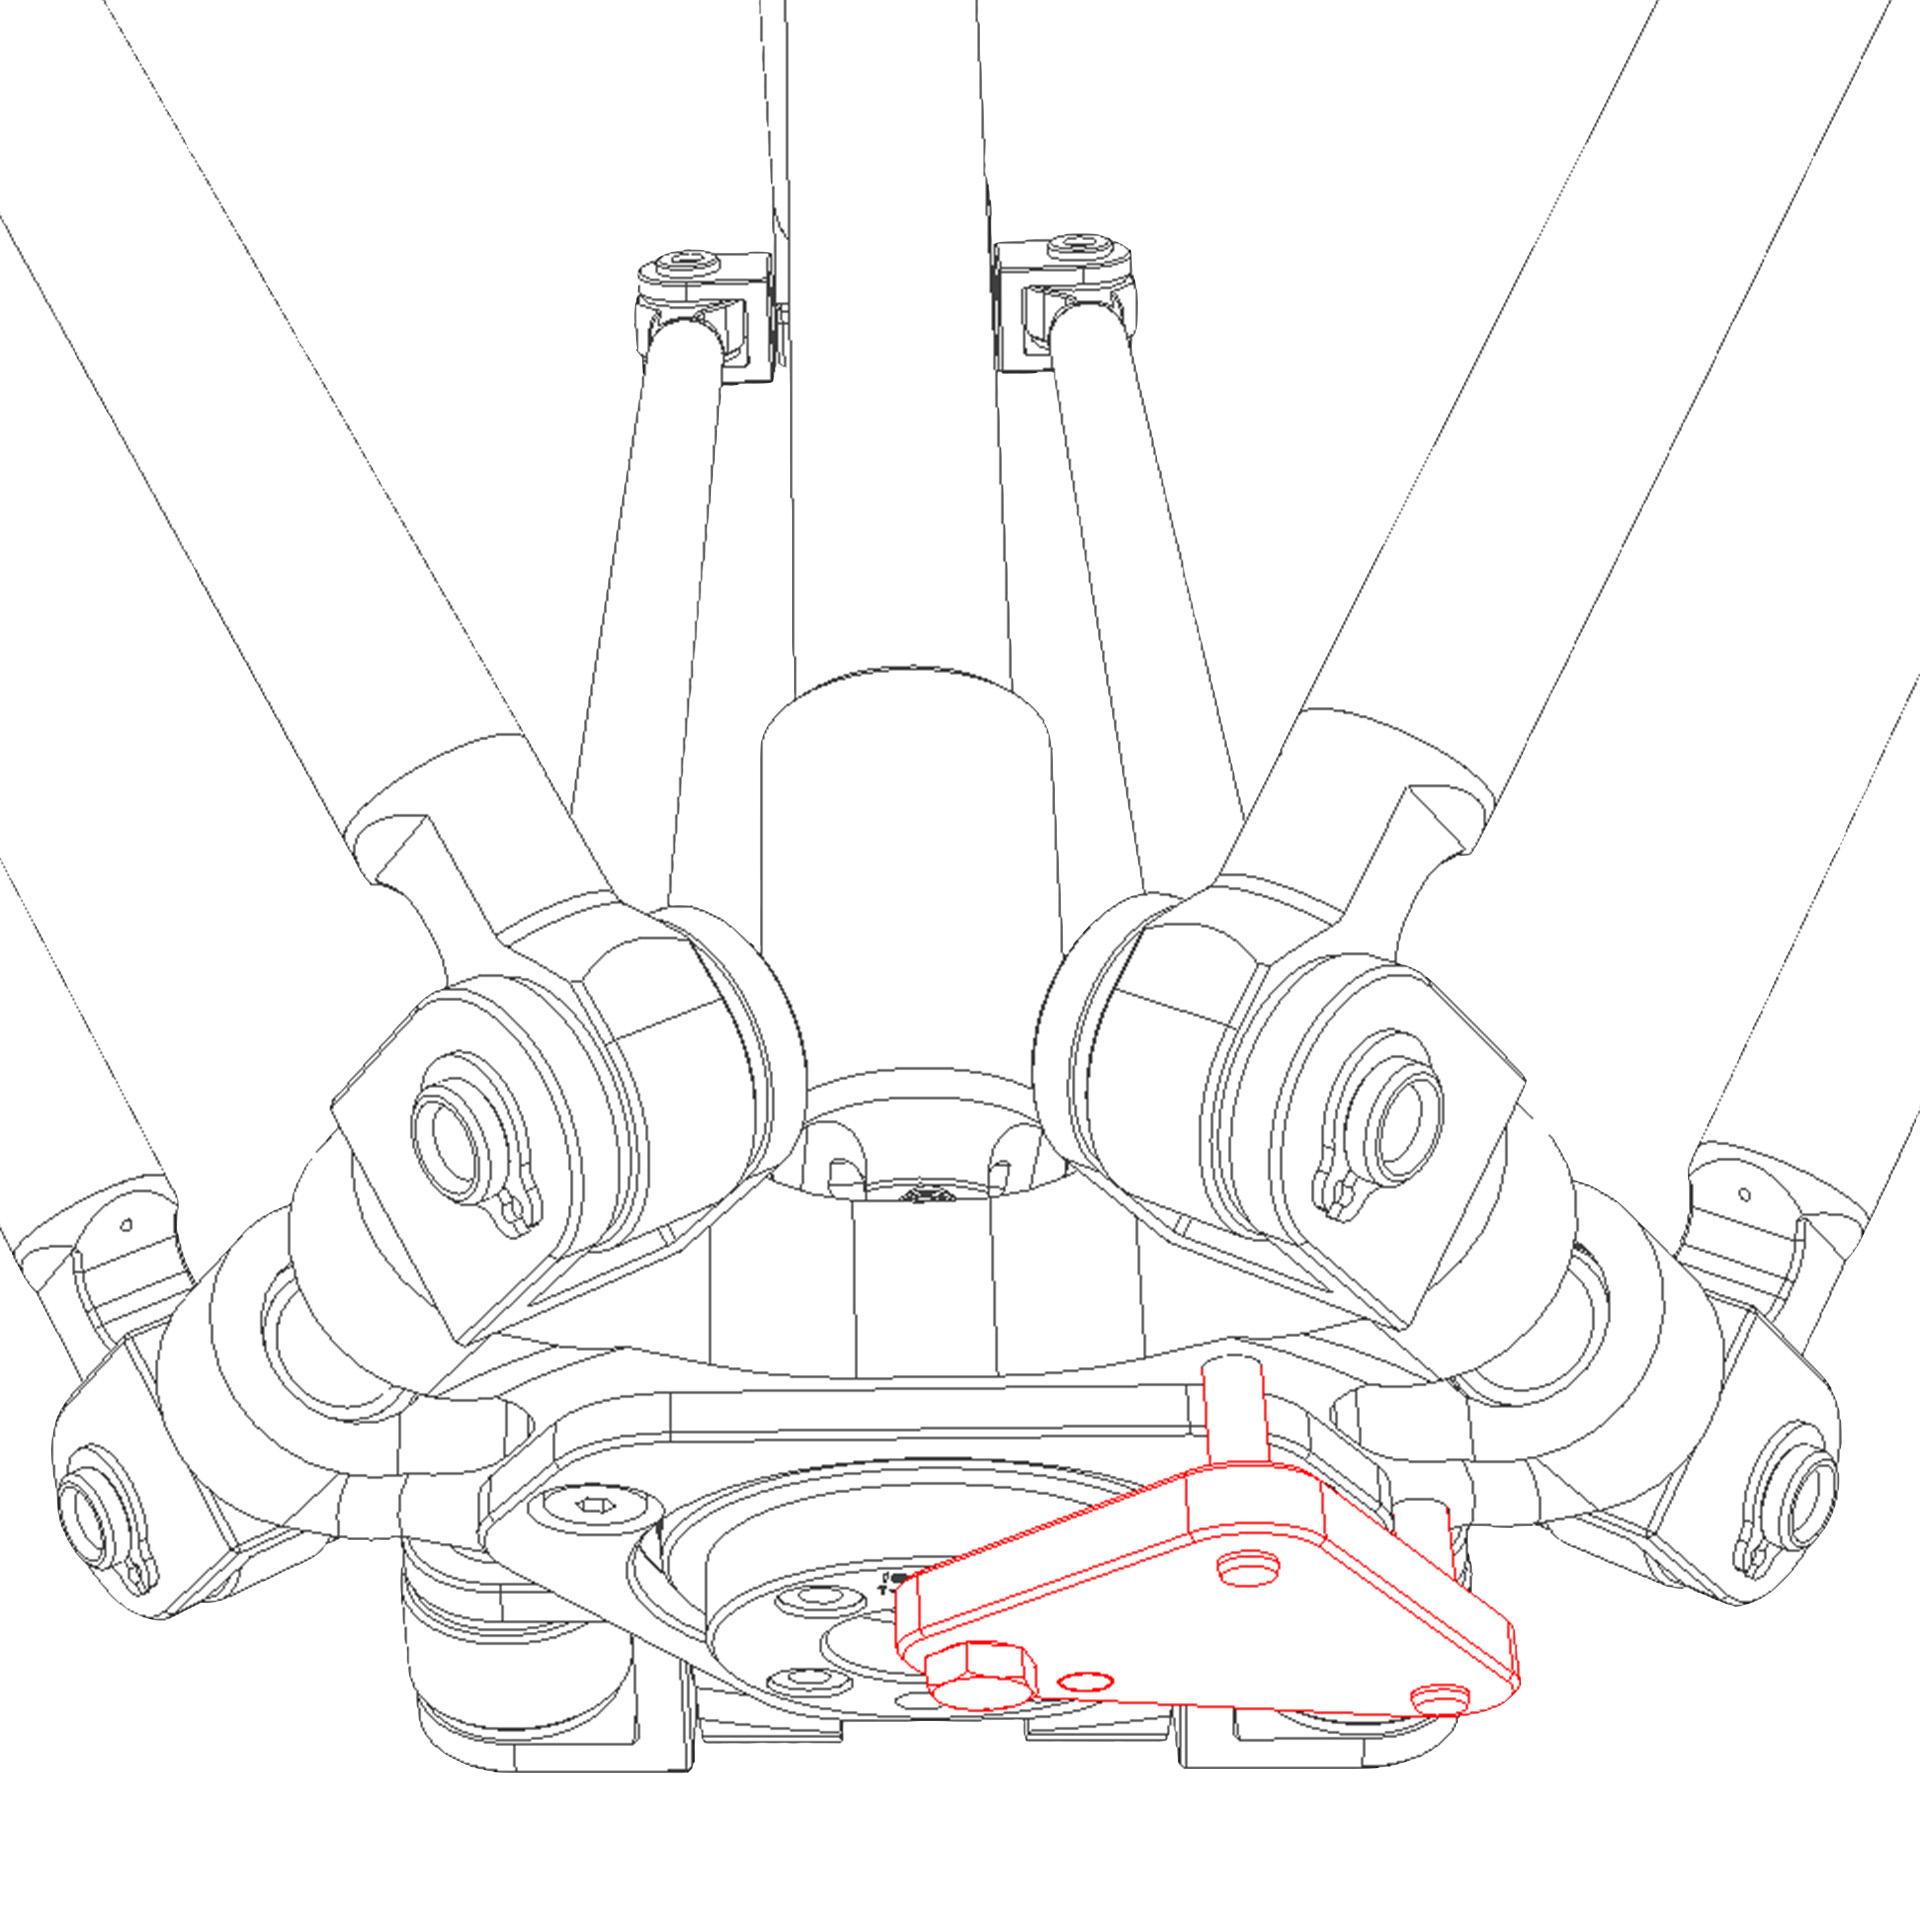
- Calibration device
- Mounting set (consisting of: Screw(s) and/or pin(s))
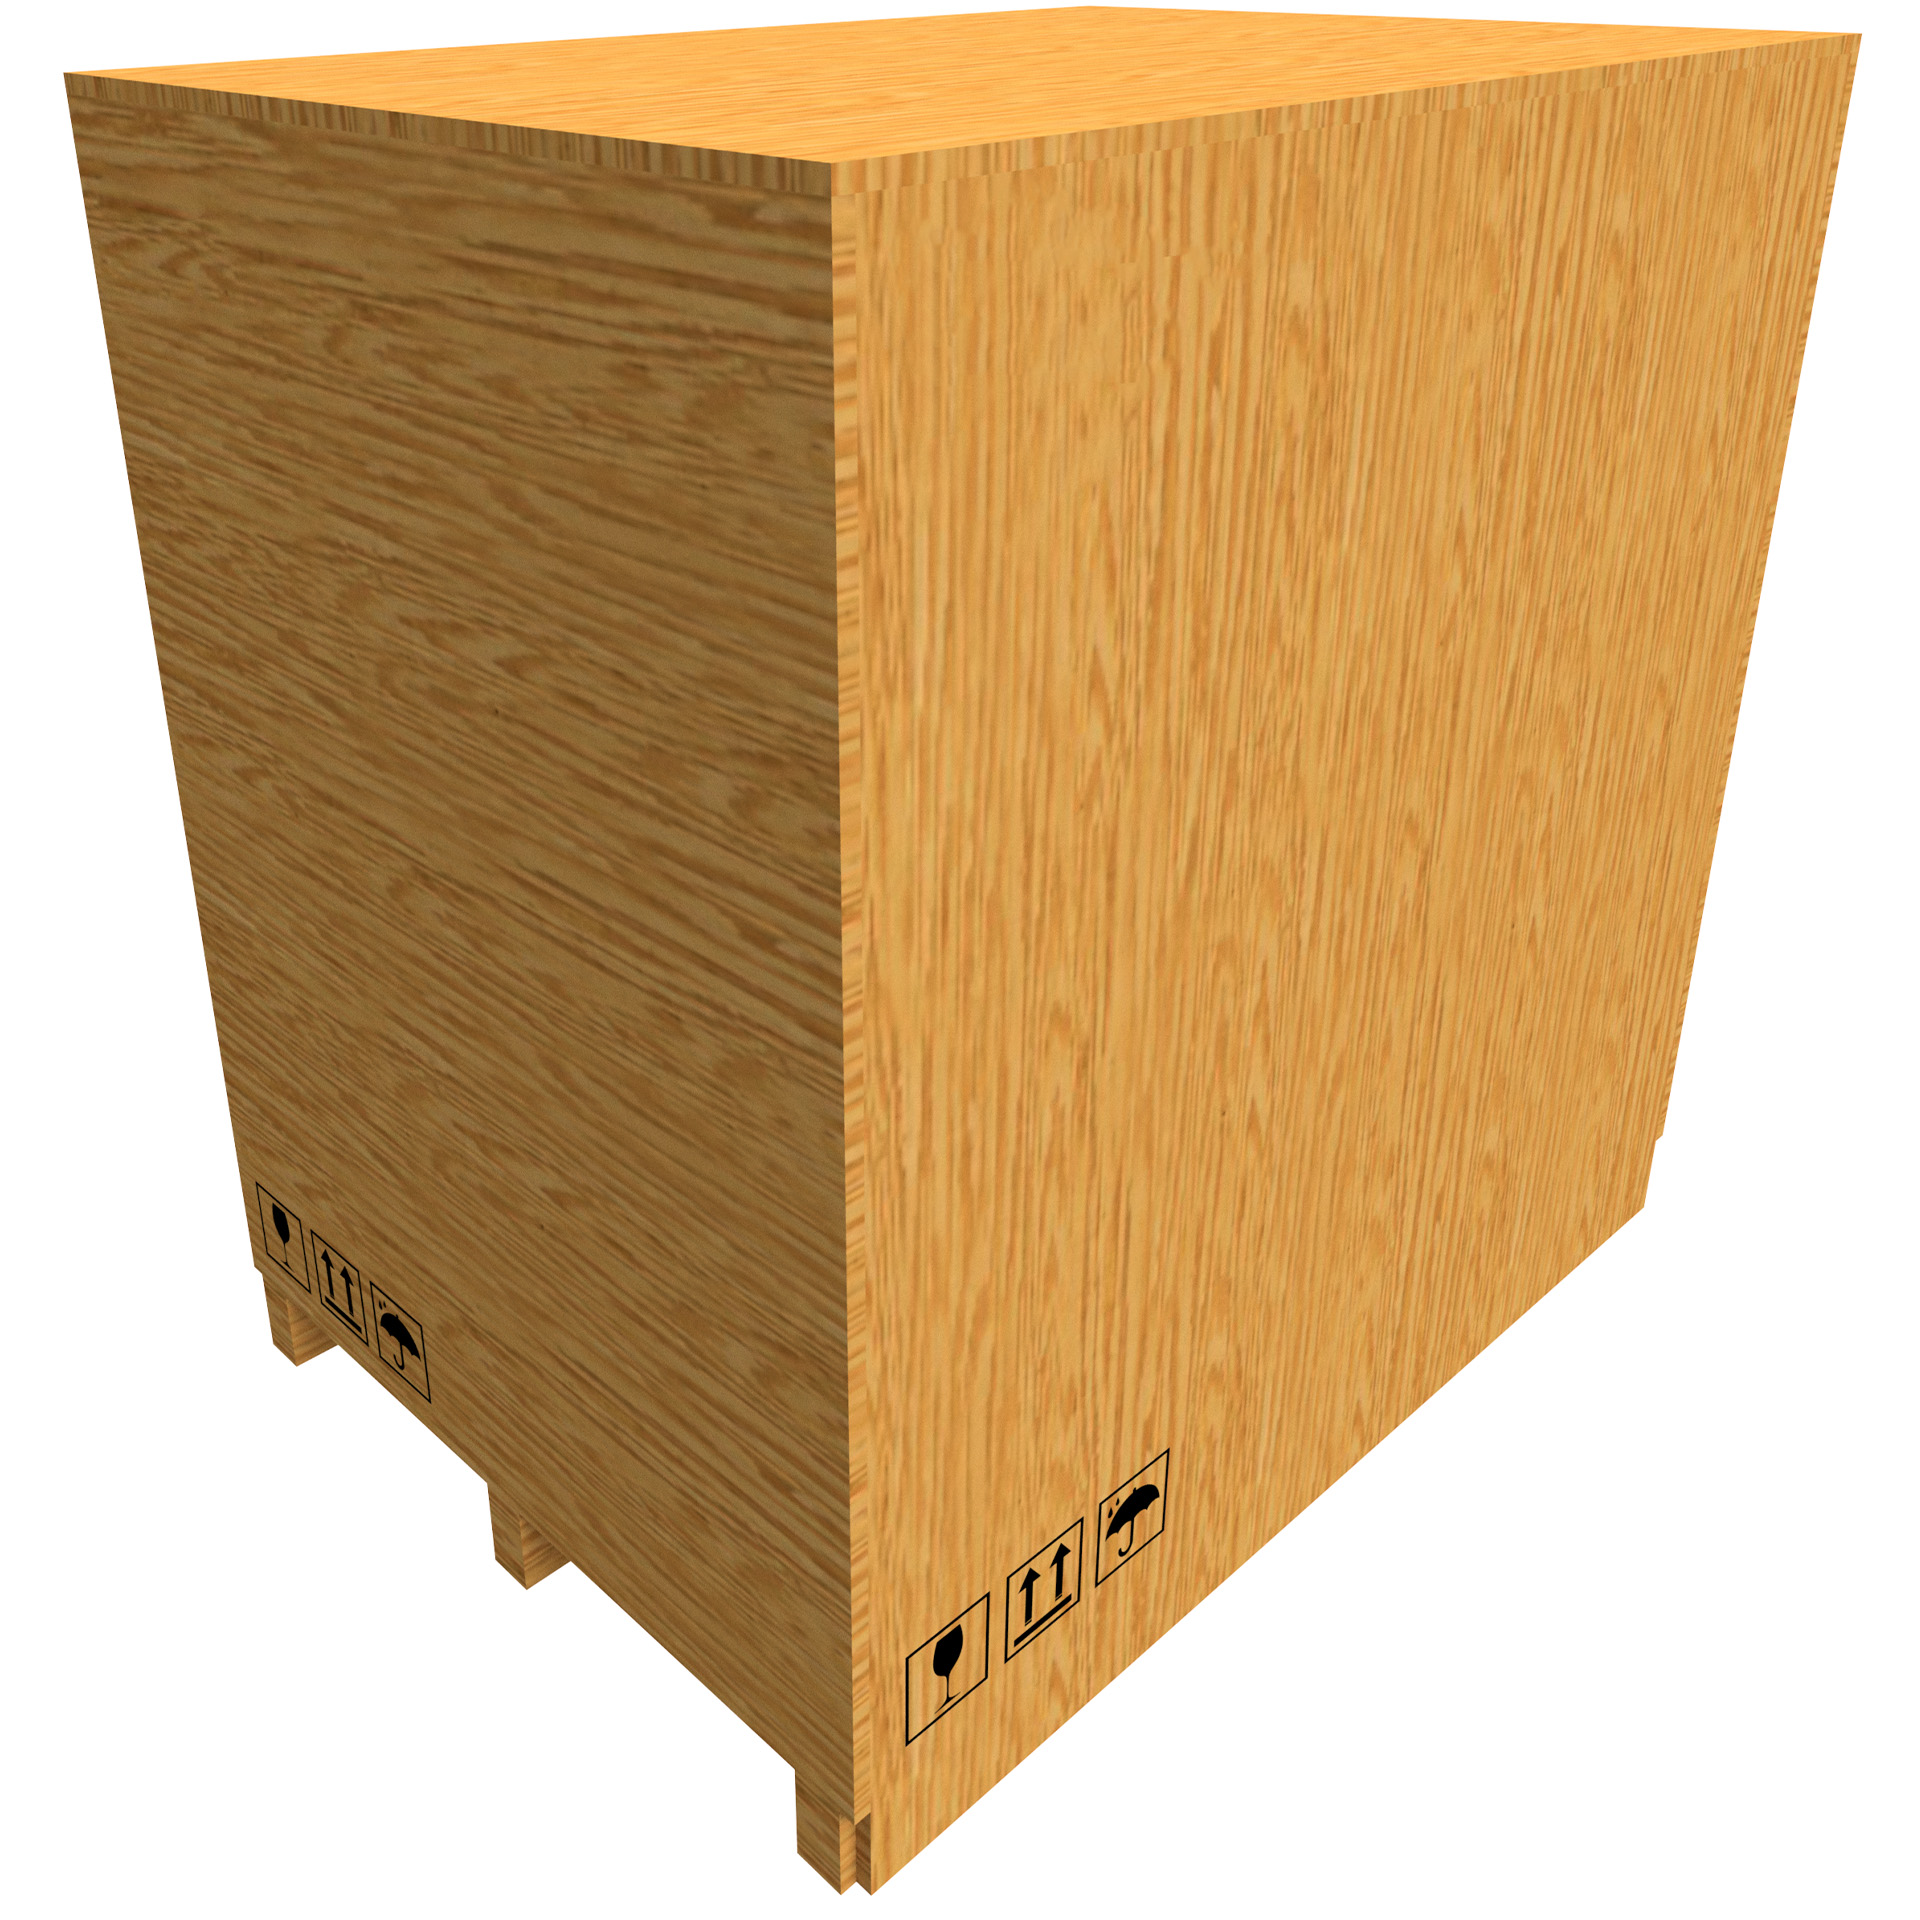
This carrier box is necessary for transporting the robot mechanics. It can be used for transport by land, air and sea.
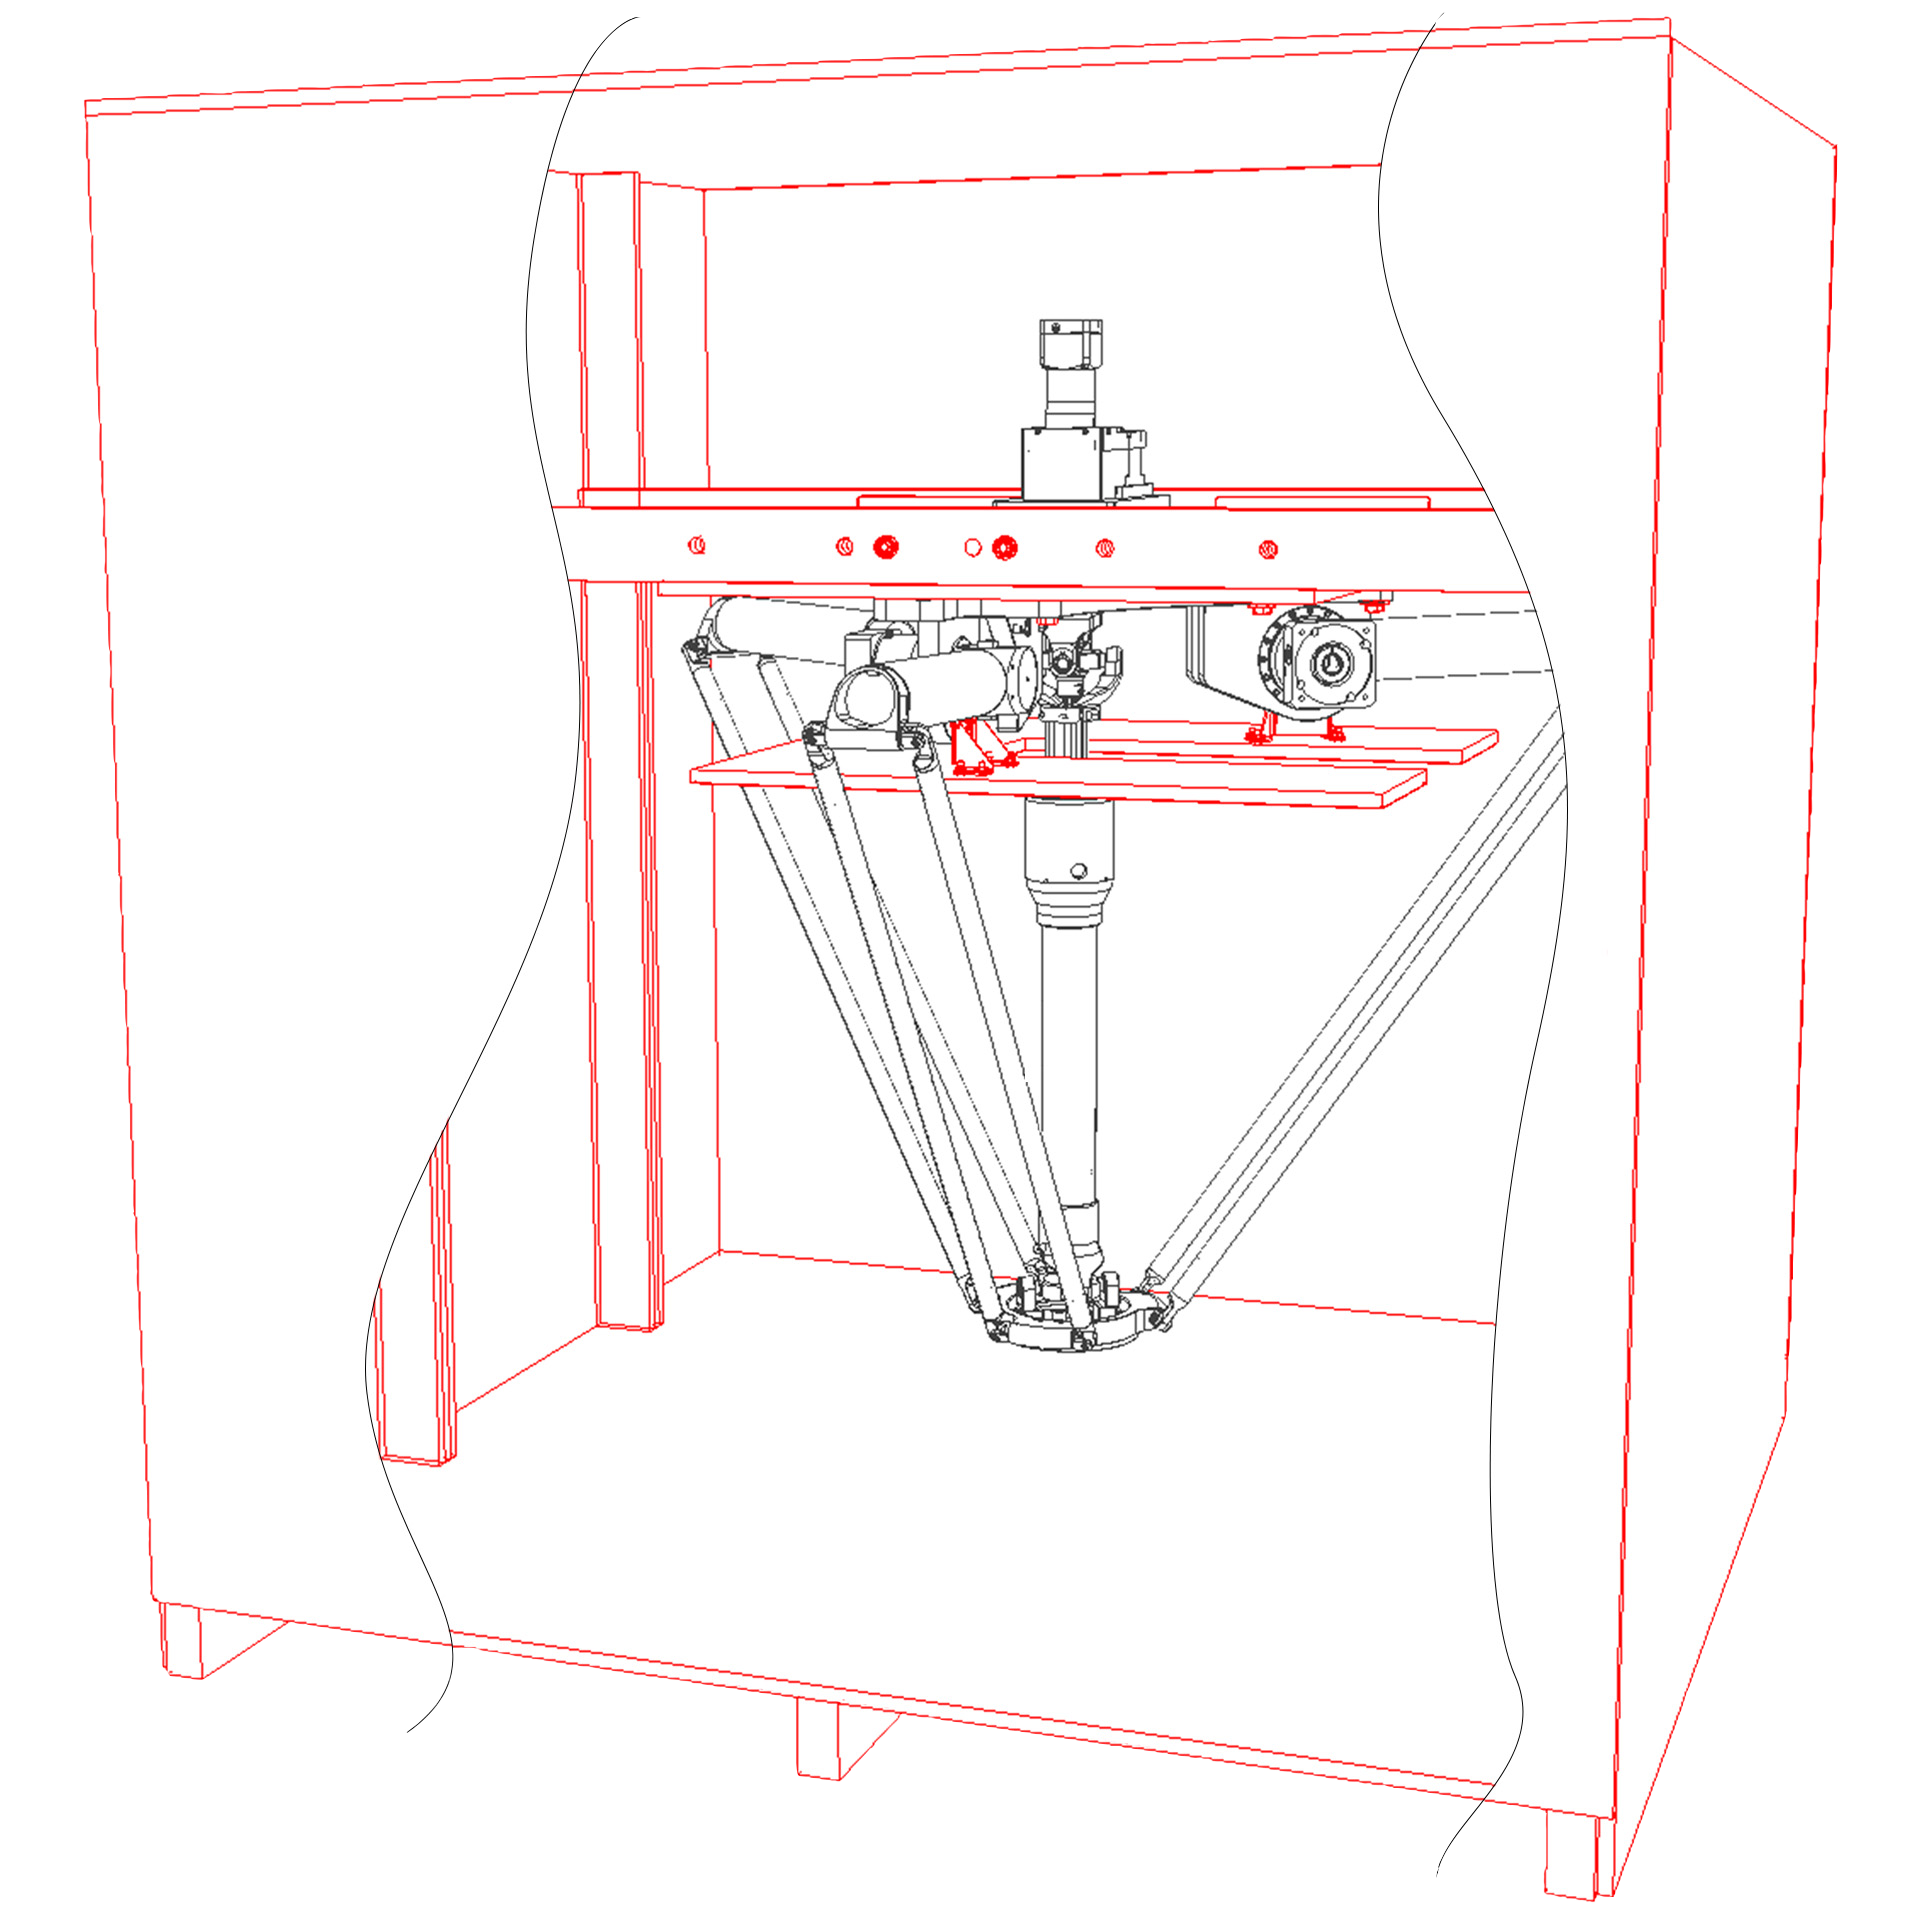
- Carrier box incl. assembling/transport aid
- Gearbox locks
This type of robot is based on the principle of parallel kinematics.
All drives are mounted in a fixed position on the robot head. Motor cables are not moved. The robot has three (3) translational and one (1) rotational degree(s) of freedom.
Scope of delivery
- Robot mechanics incl. gearbox
- Servo motor adapter
- Transport and packing instructions
Note: The operating instructions and documentation on commissioning, service, maintenance, etc. are available in the password-protected download area of the respective product page (www.autonoxfinder.com).
| Field of application: | Hygienic ′HHD′ |
|---|---|
| Kinematics: | Parallel |
| Translatory Degrees of Freedom (X,Y,Z): | 3 |
| Rotational Degrees of Freedom (α,ß,γ): | 1 |
| Nominal payload [kg|lbs]: | 3 | 6.6 |
| Working area-width X/Y [mm|in]: | 805/1250 | 31.7/49.2 |
| Working height outside [mm|in]: | 150 | 5.9 |
| Working height center [mm|in]: | 250 | 9.8 |
| Max. acceleration torque of the rotation γ around Z at the output [Nm|in.lbs]: | 6 | 53.1 |
| Nominal torque of the rotation γ around Z at the output [Nm|in.lbs]: | 4,8 | 42.5 |
| Max. speed of the rotation γ around Z at the output [1/min]: | 800 |
| Nominal speed of the rotation γ around Z at the output [1/min]: | 460 |
| Bearing type of the telescopic shaft(s): | Roller bearing |
| Bearing type of the arm joints: | Roller bearing |
| Lubricants of the bearings: | Food-grade (FO) |
| Lubricants of the gearboxes: | Gearbox of the upper arms: Synthetic; gearbox of the telescopic shaft: Food-grade (FO) |
| Cleaning: | Up to 28 bar | 406 psi high pressure |
| Protection class: | IP69K |
| Ambient temperature [°C|°F]: | 0 to +40 | +32 to +104 |
| Relative humidity level [%]: | 95 (free of condensation) |
| Mounting position: | Ceiling, Wall (on request), Angle (on request) |

Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | 8LSA36.DB060D200-3 |
| M2 | 8LSA36.DB060D200-3 |
| M3 | 8LSA36.DB060D200-3 |
| M4 | 8LSA26.D9060D200-3 |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | AM8042-0F21 |
| M2 | AM8042-0F21 |
| M3 | AM8042-0F21 |
| M4 | AM8023-0E21 |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | MS2S05-B0BTN-IMHG1-NNDNN-NN |
| M2 | MS2S05-B0BTN-IMHG1-NNDNN-NN |
| M3 | MS2S05-B0BTN-IMHG1-NNDNN-NN |
| M4 | MS2S03-B0BYN-IMHG1-NNDNN-NN |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
| M2 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
| M3 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
| M4 | ISD-520D6-01T5XX+FAHB+FCSS+FD11+FFM1+FG070+FN60+FSSS |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | TA3S V60 BP05 EN01 PT |
| M2 | TA3S V60 BP05 EN01 PT |
| M3 | TA3S V60 BP05 EN01 PT |
| M4 | TA1M V60 BP03 EN01 PT |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | DMS2-091-0035-60-B1xxG1-Q000-0 |
| M2 | DMS2-091-0035-60-B1xxG1-Q000-0 |
| M3 | DMS2-091-0035-60-B1xxG1-Q000-0 |
| M4 | DMS2-058-0012-60-B1xxG1-Q000-0 |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | MCS09D60-EKMP1-Axxx-xx6xxx-xxxx |
| M2 | MCS09D60-EKMP1-Axxx-xx6xxx-xxxx |
| M3 | MCS09D60-EKMP1-Axxx-xx6xxx-xxxx |
| M4 | MCS06C60-EKMP1-Axxx-xx6xxx-xxxx |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | VPL-B1003T-PK14AA |
| M2 | VPL-B1003T-PK14AA |
| M3 | VPL-B1003T-PK14AA |
| M4 | VPL-B0633M-PK14AA |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | CMP63S/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.100 |
| M2 | CMP63S/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.100 |
| M3 | CMP63S/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.100 |
| M4 | CMP40M/BK/PK/AK0H/SB1 / Mat-Nr. 84207209.800 |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation 1) |
Article number motor manufacturer (Recommendation 2) | Article number motor manufacturer (Recommendation 3) |
|---|---|---|---|
| M1 | 1FK2105-4AF11-0MA0 | 1FK2105-4AF11-0MB0 | 1FK7042-2AK71-1RH2 |
| M2 | 1FK2105-4AF11-0MA0 | 1FK2105-4AF11-0MB0 | 1FK7042-2AK71-1RH2 |
| M3 | 1FK2105-4AF11-0MA0 | 1FK2105-4AF11-0MB0 | 1FK7042-2AK71-1RH2 |
| M4 | 1FK2203-4AK10-2MA0 | 1FK2203-4AK10-2MB0 | 1FK7022-5AK71-1LH5 |
No motors are currently defined. Enquire here
Motor |
Article number motor manufacturer (Recommendation) |
|---|---|
| M1 | SGM7A-10D7F2C |
| M2 | SGM7A-10D7F2C |
| M3 | SGM7A-10D7F2C |
| M4 | SGM7A-04D7F2C |
No motors are currently defined. Enquire here
-
Signed in / logged in you will receive further documents:
Note: If the documentation in the download area is not yet complete, please contact us (info@autonox.com).
This device is used to calibrate our robot mechanics. A defined motor position (encoder value) is assigned to the respective mechanical axis position. The calibration instructions can be found in the download area of the respective robot mechanics.
- Calibration device
- Mounting set (consisting of: Screw(s) and/or pin(s))
This carrier box is necessary for transporting the robot mechanics. It can be used for transport by land, air and sea.
- Carrier box incl. assembling/transport aid
- Gearbox locks